Reliability-Aware FastSAM-DINOv2 Framework for Urban Freight Loading Bay Occupancy Prediction from Roadside Cameras and Order Records
Authors
Files
Key Information
Journal
Published in Vol. 4 No. 3 (2026) of Journal of Data‑Centric Engineering Science.
Journal of Data‑Centric Engineering Science eISSN 3136-814X is an international, peer‑reviewed open‑access journal. It publishes high‑quality original research, methodological advances, comprehensive reviews, dataset papers and short communications concerning fundamental theories, scientific methodologies and cross‑domain engineering applications under the data‑centric paradigm. This journal focuses on underlying scientific problems of data‑driven engineering, promotes the integration of data science and physical‑mechanism‑based engineering science, and builds an interdisciplinary platform for academic researchers and industrial scientists.
About the JournalAbstract
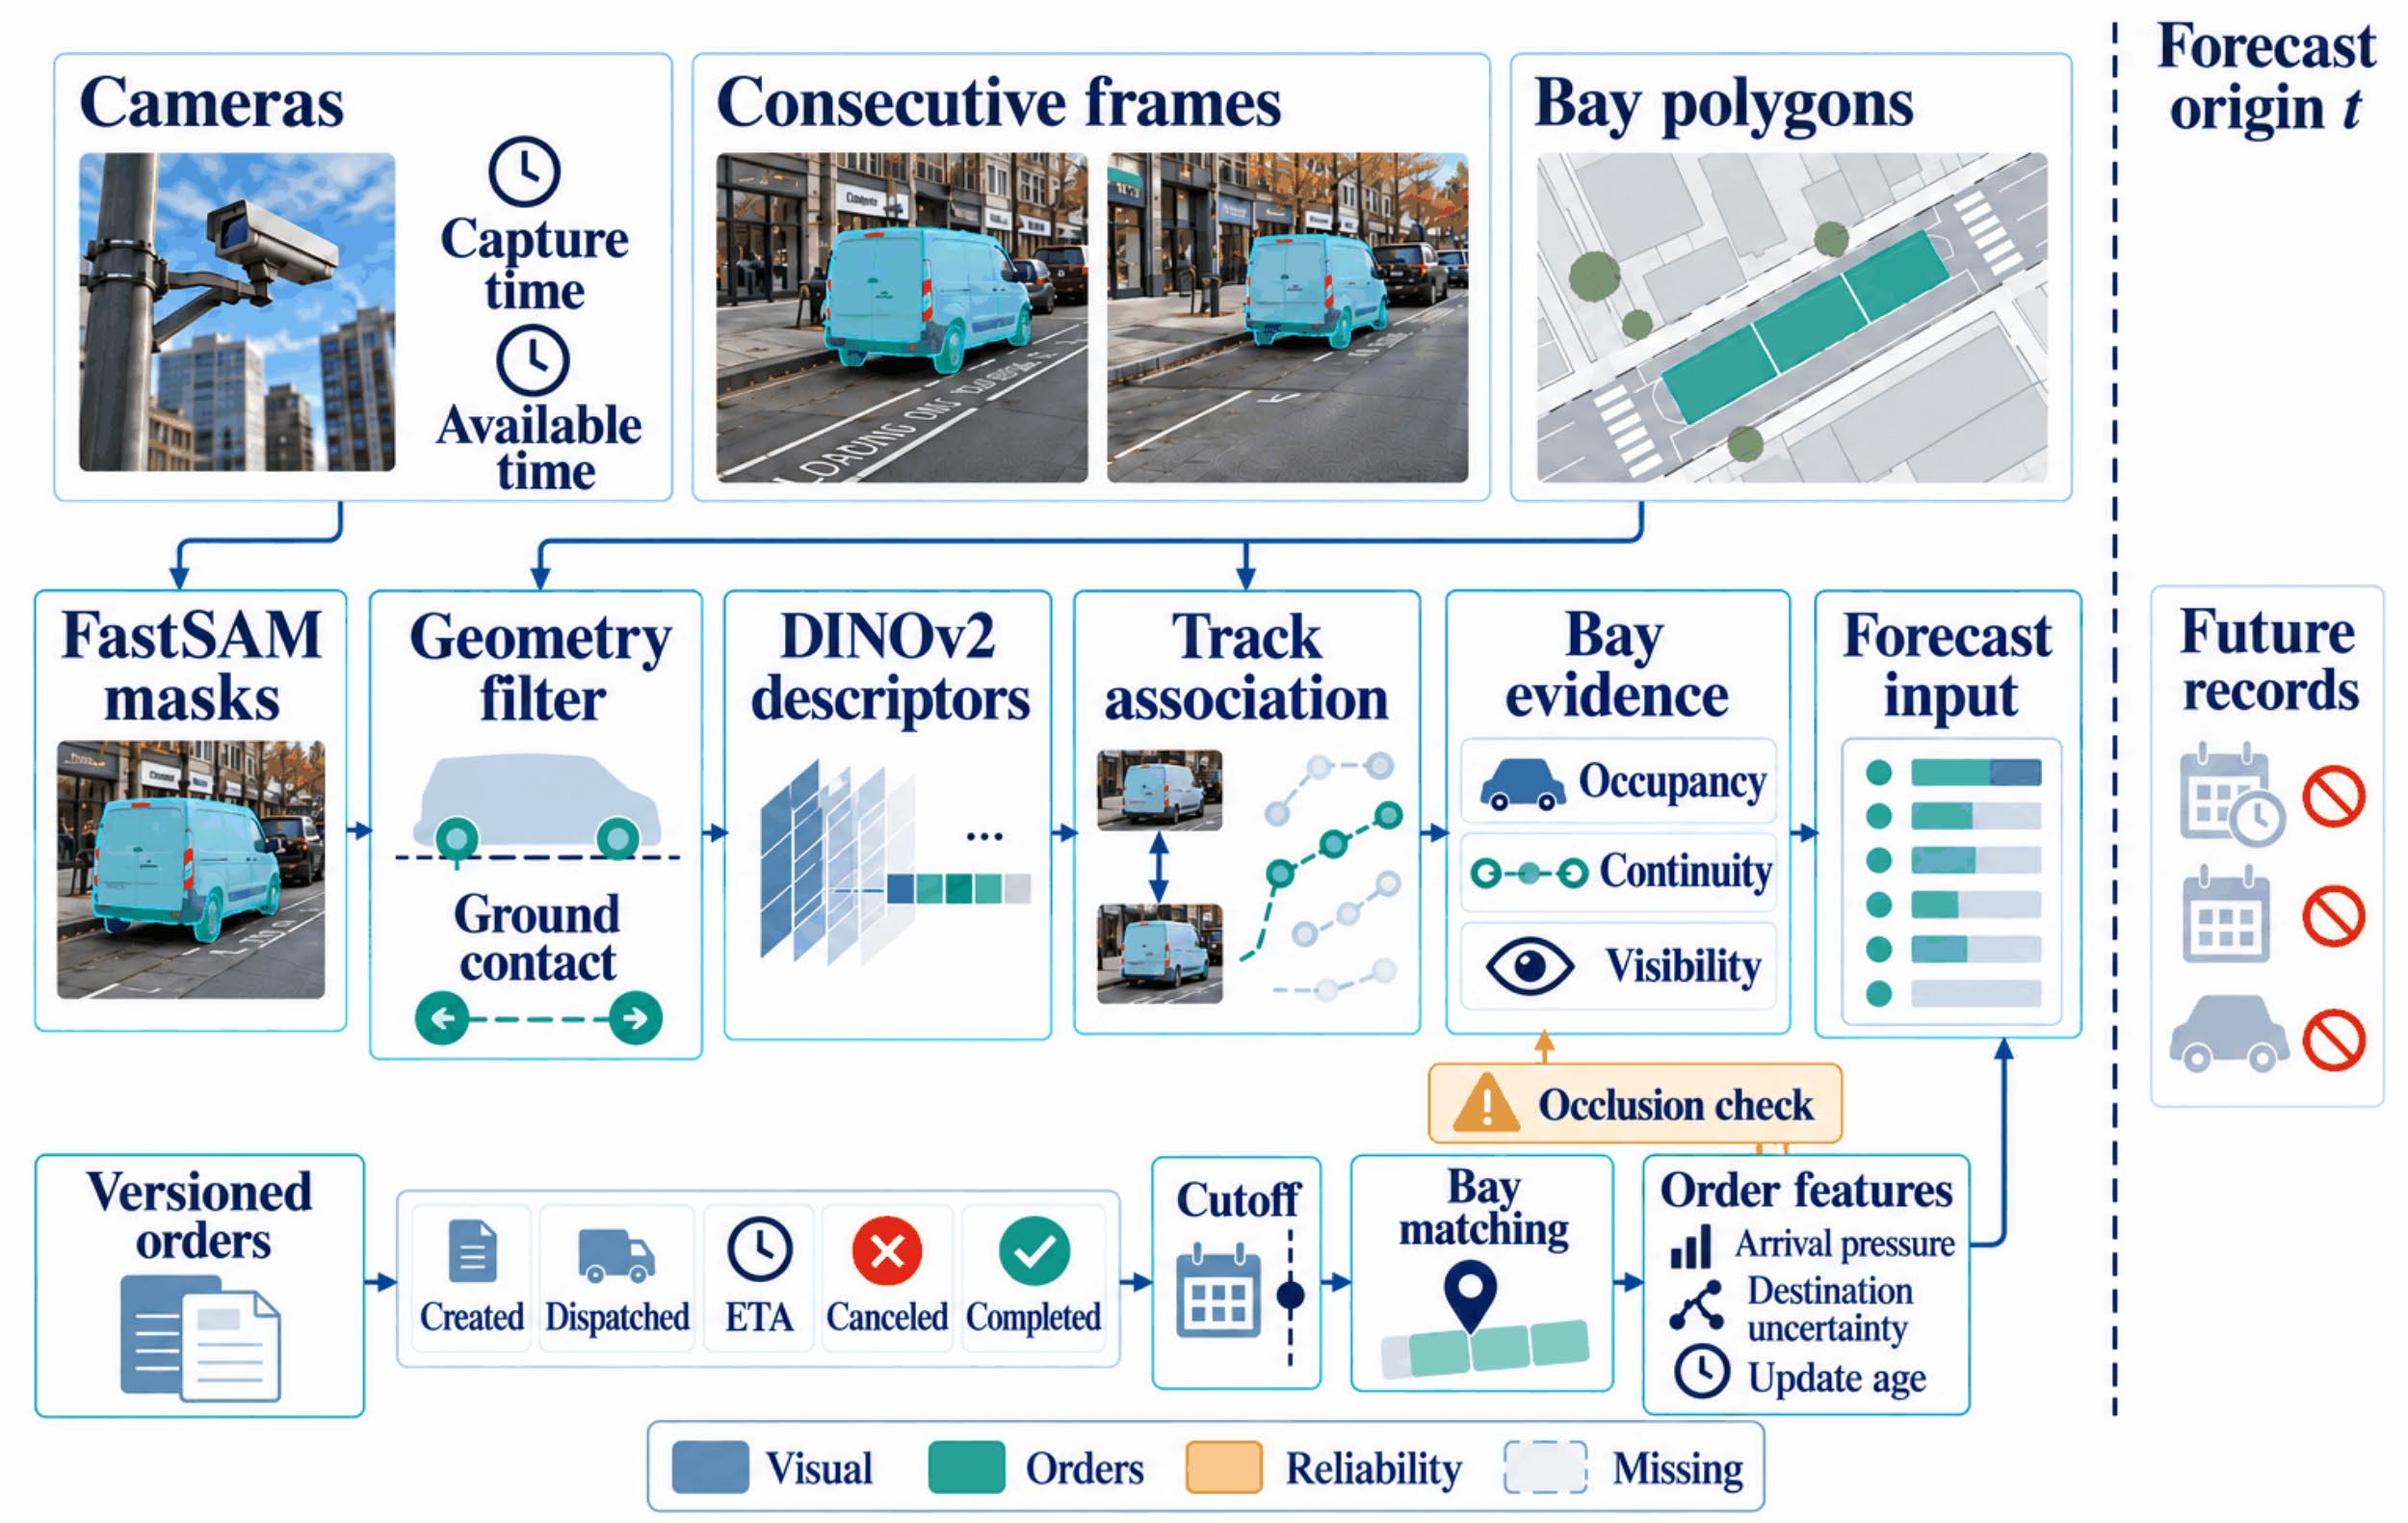
Urban freight loading bays experience uncertain arrivals and variable service durations, while roadside cameras provide incomplete observations. This paper specifies a reliability-aware FastSAM-DINOv2 framework for predicting individual- bay occupancy from roadside images and order records available at forecast issuance. The design combines instance masks, frozen self-supervised visual descriptors, persistent bay association, and a gate that adjusts the contributions of visual and order features. A causal temporal encoder produces occupancy probabilities at horizons of 5, 10, 15, 20, and 30 minutes, followed by horizon-specific temperature scaling. Physical occupancy is distinguished from registered freight demand, and separate event and availability timestamps define the information boundary. The scheduled evaluation grid contains 24 bays, 60 days, 288 daily intervals, and 414,720 bay-time records before label and horizon exclusions. Reported configuration summaries give a 15-minute mean absolute probability error of 0.109 for the proposed design and 0.146 for unmodified fusion, a descriptive relative reduction of 25.3%. Corresponding Brier scores are 0.087 and 0.124. The reported error at 30% camera loss is 0.135, without a documented matched comparator under that condition. The contribution is an integrated specification linking observation reliability, causal order alignment, and occupancy forecasting. Operational effectiveness remains to be tested using versioned records, independent physical labels, complete implementation settings, and a prospective deployment protocol.
Details
License
Copyright (c) 2026 Bülent Ekin, Oktay Savaş

This work is licensed under a Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License.
