Spherical Epipolar Cost Aggregation for ACVNet-Based Fisheye Stereo Depth Estimation
Authors
Emil Pawlak, Marcin Chmielewski, Sebastian Zalewski, Leon KamińskiFiles
Key Information
Journal
Published in Vol. 4 No. 2 (2026) of Journal of Applied Computational Intelligence.
The Journal of Applied Computational Intelligence (JACI) eISSN:3136-6937 is a peer-reviewed, international, open-access journal dedicated to the advancement of computational intelligence methodologies and their real-world applications across diverse engineering and scientific domains. The journal aims to bridge the gap between theoretical development and practical deployment of intelligent systems by providing a scholarly platform for researchers, practitioners, and industry innovators.
JACI encourages high-quality original research, review articles, and technical reports that explore the design, implementation, and optimization of intelligent algorithms for solving complex problems in fields such as manufacturing, energy, healthcare, transportation, and information systems.
Abstract
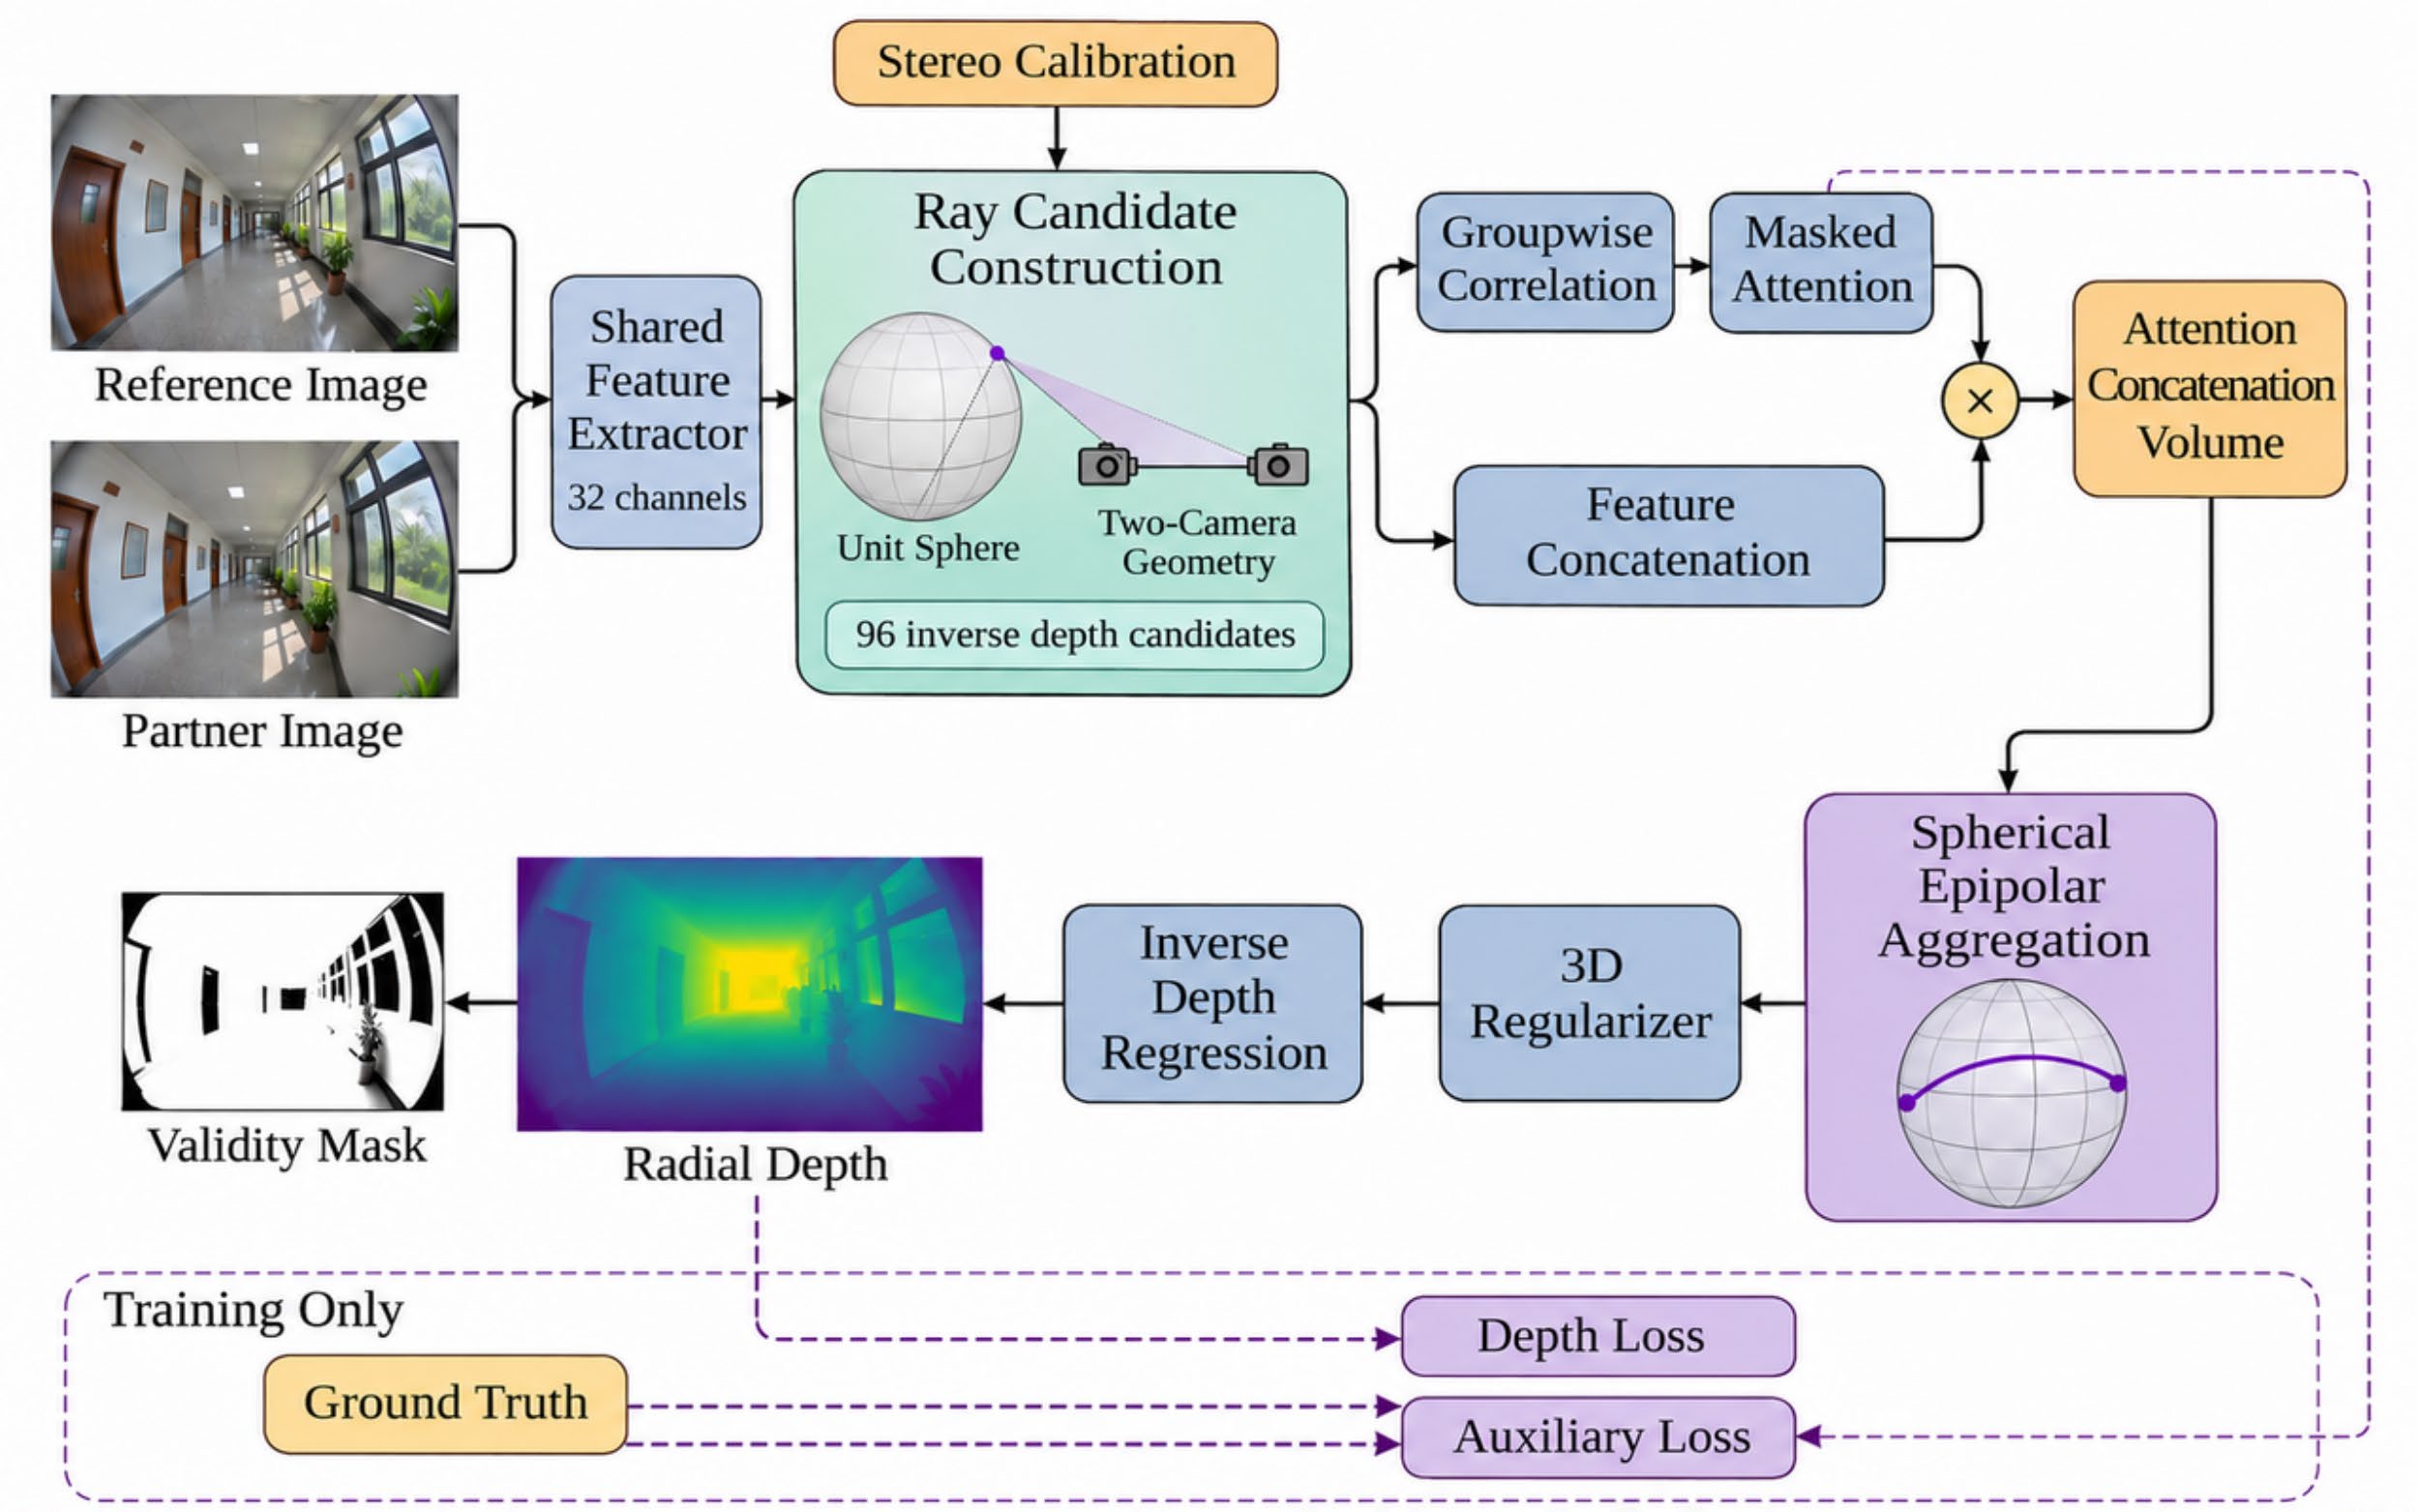
Fisheye stereo cameras provide a wide field of view, while their nonlinear projection complicates correspondence search and introduces spatial variation into conventional aggregation neighborhoods. This paper presents a spherical epipolar extension of an attention concatenation volume network for depth estimation directly from calibrated fisheye images. The proposed design samples candidate correspondences through calibrated rays, constructs correlation-guided attention over inverse depth, and aggregates evidence within depth-conditioned spherical epipolar neighborhoods. A validity mask excludes unsupported samples, and a residual gate controls the propagation of ambiguous costs. Evaluation uses a common candidate grid to examine overall accuracy, angular dependence, component contributions, calibration sensitivity, and computational cost. Absolute relative depth error decreases from 0.142 for the projection-adapted baseline to 0.109 for the full design, and the proportion of pixels exceeding ten percent relative error decreases from 18.6% to 13.4%. Peripheral error decreases from 0.201 to 0.139, accompanied by a latency increase from 46 to 54 ms per stereo pair. The ordered component sequence shows its largest individual step after validity gating; the contributions of spherical support remain conditional on preceding modules. Perturbation results indicate calibration sensitivity. The formulation connects attention- based matching with fisheye geometry and provides a framework for evaluating accuracy and computational tradeoffs. The analysis identifies peripheral support alignment, candidate resolution, and calibration stability as interconnected factors in wide-field stereo depth estimation. Interpretation of the reported comparisons requires documented data provenance and execution details for independent validation.
References
Roghani, S. E. S., & Koyuncu, E. (2024). Canonical trinocular camera setups and fisheye view for enhanced feature-based visual aerial odometry. IEEE Access, 12, 134888–134901. https://doi.org/10.1109/access.2024.3456909
Zhu, H., Zhang, G., Ye, Z., & Zhou, H. (2024). LVIF: A lightweight tightly coupled stereo-inertial SLAM with fisheye camera. Complex & Intelligent Systems, 10(1), 763–780. https://doi.org/10.1007/s40747-023-01190-5
Simioni, E., Pernechele, C., Erb, W., Marchini, A., Martini, P., Lessio, L., Penasa, L., & Beghini, M. (2024). A-central model for the geometric calibration of hyper-hemispherical lenses. Optics Express, 32(20), 34777–34795. https://doi.org/10.1364/oe.527318
Zhou, G., Tang, Y., Xie, Y., Song, R., Zhu, Q., & Zhou, X. (2024). Calibration of fisheye camera with colinear constraint of the main optical axis and epipolar line orthogonality-transverse axis. IEEE Sensors Journal, 24(12), 19373–19384. https://doi.org/10.1109/jsen.2024.3392810
Zhang, Y., Ma, Y., Wu, Y., & Liu, L. (2024). Achieving widely distributed feature matches using flattened-affine-SIFT algorithm for fisheye images. Optics Express, 32(5), 7969–7986. https://doi.org/10.1364/oe.513531
Jiang, H., Xu, R., Tan, M., & Jiang, W. (2024). RomniStereo: Recurrent omnidirectional stereo matching. IEEE Robotics and Automation Letters, 9(3), 2511–2518. https://doi.org/10.1109/lra.2024.3357315
Chen, Q., Ge, B., & Quan, J. (2024). Unambiguous pyramid cost volumes fusion for stereo matching. IEEE Transactions on Circuits and Systems for Video Technology, 34(10), 9223–9236. https://doi.org/10.1109/tcsvt.2023.3291726
Xu, G., Wang, X., Zhang, Z., Cheng, J., Liao, C., & Yang, X. (2025). IGEV++: Iterative multi-range geometry encoding volumes for stereo matching. IEEE Transactions on Pattern Analysis and Machine Intelligence, 47(8), 7108–7122. https://doi.org/10.1109/tpami.2025.3569218
Xu, G., Wang, Y., Cheng, J., Tang, J., & Yang, X. (2024). Accurate and efficient stereo matching via attention concatenation volume. IEEE Transactions on Pattern Analysis and Machine Intelligence, 46(4), 2461–2474. https://doi.org/10.1109/tpami.2023.3335480
Liao, Z., Zhou, W., & Li, H. (2024). DaFIR: Distortion-aware representation learning for fisheye image rectification. IEEE Transactions on Circuits and Systems for Video Technology, 34(5), 3606–3618. https://doi.org/10.1109/tcsvt.2023.3315967
Liu, Y., Cai, Q., Wang, C., Yang, J., Fan, H., Dong, J., & Chen, S. (2024). Geometry-enhanced attentive multi-view stereo for challenging matching scenarios. IEEE Transactions on Circuits and Systems for Video Technology, 34(8), 7401–7416. https://doi.org/10.1109/tcsvt.2024.3376692
Chou, C.-H., & Tsao, L.-H. (2025). Automatic calibration of multiple fisheye cameras using recovered human body mesh. Electronic Imaging, 37(10), 347-1–347-8. https://doi.org/10.2352/ei.2025.37.10.ipas-347
Liang, Z., & Li, C. (2024). Any-Stereo: Arbitrary scale disparity estimation for iterative stereo matching. Proceedings of the AAAI Conference on Artificial Intelligence, 38(4), 3333–3341. https://doi.org/10.1609/aaai.v38i4.28119
Wang, S., Li, B., & Dai, Y. (2024). Efficient multi-view stereo by dynamic cost volume and cross-scale propagation. IEEE Transactions on Circuits and Systems for Video Technology, 34(10), 9414–9427. https://doi.org/10.1109/tcsvt.2024.3398060
Zhou, J., Lin, C., Yang, S., Liao, K., & Zhao, Y. (2025). Calibrating the principal point of vehicle-mounted fisheye cameras using point-oriented representation. IEEE Sensors Journal, 25(11), 19602–19612. https://doi.org/10.1109/jsen.2025.3555836
Wang, Y., Wang, L., Li, K., Zhang, Y., Wu, D. O., & Guo, Y. (2024). Cost volume aggregation in stereo matching revisited: A disparity classification perspective. IEEE Transactions on Image Processing, 33, 6425–6438. https://doi.org/10.1109/tip.2024.3484251
Okae, J., & Qin, H. (2024). DMCNet: Toward lightweight volumetric stereo matching. IEEE Sensors Journal, 24(7), 11936–11945. https://doi.org/10.1109/jsen.2024.3368028
Jin, L., & Xu, K. (2025). MAF-Stereo: Fast stereo matching through multi-branch attention fusion. ISA Transactions, 164, 211–221. https://doi.org/10.1016/j.isatra.2025.05.038
Li, P., Yao, C., Jia, Y., & Wu, Y. (2025). Inter-scale similarity guided cost aggregation for stereo matching. IEEE Transactions on Circuits and Systems for Video Technology, 35(1), 134–147. https://doi.org/10.1109/tcsvt.2024.3453965
Pathak, S., Hamada, T., & Umeda, K. (2024). Trinocular 360-degree stereo for accurate all-round 3D reconstruction considering uncertainty. Advanced Robotics, 38(15), 1038–1051. https://doi.org/10.1080/01691864.2024.2376022
Tosi, F., Bartolomei, L., & Poggi, M. (2025). A survey on deep stereo matching in the twenties. International Journal of Computer Vision, 133(7), 4245–4276. https://doi.org/10.1007/s11263-024-02331-0
Lee, J. Y., Ka, W., Choi, J., & Kim, J. (2024). Modeling stereo-confidence out of the end-to-end stereo-matching network via disparity plane sweep. Proceedings of the AAAI Conference on Artificial Intelligence, 38(4), 2901–2910. https://doi.org/10.1609/aaai.v38i4.28071
Xu, Y., & Dong, Q. (2026). Distortion-aware depth self-updating for self-supervised fisheye monocular depth estimation. IEEE Transactions on Image Processing, 35, 1883–1898. https://doi.org/10.1109/tip.2026.3661813
Zhang, C., Meng, G., Tian, K., Ni, B., & Xiang, S. (2024). Active disparity sampling for stereo matching with adjoint network. IEEE Transactions on Image Processing, 33, 354–365. https://doi.org/10.1109/tip.2023.3343105
Zhu, L., Rigall, E., Gao, Y., Zhang, Z., Bai, Y., & Dong, J. (2025). Region-aware driven distribution optimization for stereo matching. IEEE Transactions on Circuits and Systems for Video Technology, 35(12), 11965–11977. https://doi.org/10.1109/tcsvt.2025.3588869
Su, W., & Tao, W. (2025). Context-aware multi-view stereo network for efficient edge-preserving depth estimation. International Journal of Computer Vision, 133(6), 3367–3391. https://doi.org/10.1007/s11263-024-02337-8
Satouri, B., El Abderrahmani, A., & Satori, K. (2024). End-to-end artificial intelligence-based system for automatic stereo camera self-calibration. IEEE Access, 12, 160927–160945. https://doi.org/10.1109/access.2024.3486017
Zhang, C., Meng, G., Fan, B., Tian, K., Zhang, Z., Xiang, S., & Pan, C. (2024). Reusable architecture growth for continual stereo matching. IEEE Transactions on Pattern Analysis and Machine Intelligence, 46(9), 6167–6184. https://doi.org/10.1109/tpami.2024.3378884
Wang, Y., Li, K., Wang, L., Hu, J., Wu, D. O., & Guo, Y. (2025). ADStereo: Efficient stereo matching with adaptive downsampling and disparity alignment. IEEE Transactions on Image Processing, 34, 1204–1218. https://doi.org/10.1109/tip.2025.3540282
Park, C., Kim, J., Kweon, M., & Park, J. (2026). CAR-Stereo: Confidence-aware adaptive disparity refinement for real-time stereo matching. IEEE Robotics and Automation Letters, 11(1), 690–697. https://doi.org/10.1109/lra.2025.3634908
